
Pt heptamer island
1 The problem file does not state a run count, and the ranked rows do not agree. They record 2 on eOn; 16 on Sella; 5000 on softsaddle; 20000 on rgsaddle.
2 The problem file does not state a cap.
A 2-search SoftSaddle batch stays off this rank. The April 2019 adaptive_HSphere-lbfgs-davidson-sm50 entry records 423491.1 force calls.
The main metric is Force calls. Scoring rules.
Charts
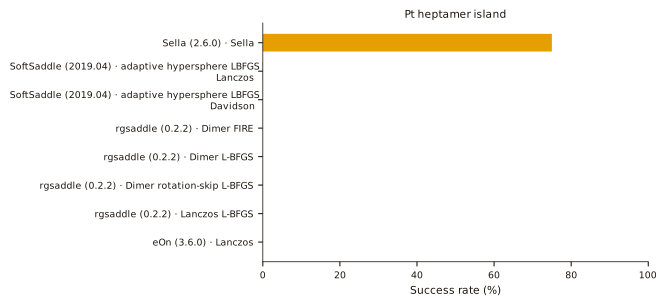
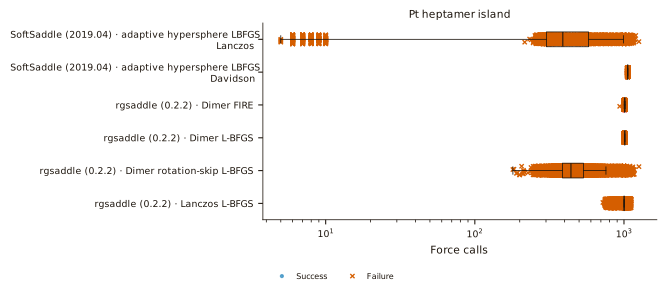
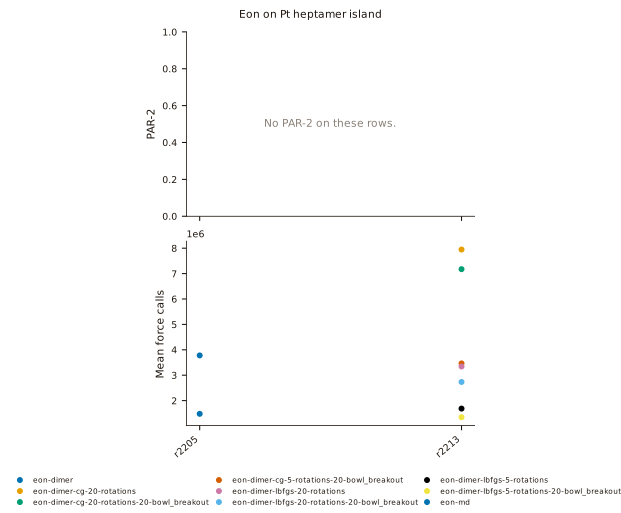
No performance profile. The ranked rows do not share one start set.
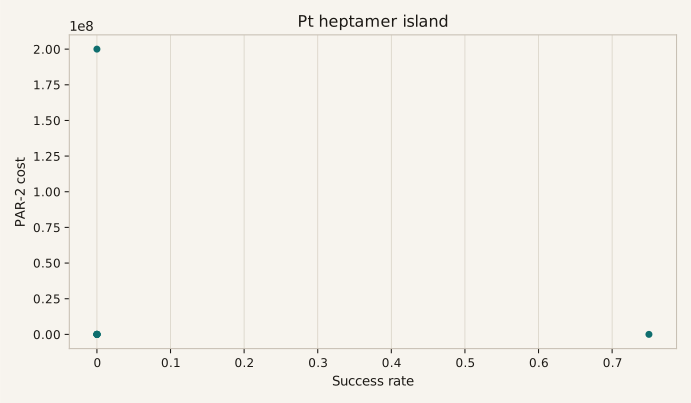
Leaderboard
| Rank | Code | Best | Median | Success | PAR-2 |
|---|---|---|---|---|---|
| 1 | Sella | 5201.62 | 75.0% | 5201.62 | |
| 2 | SoftSaddle | 10126.1 | 0.0% | 10124.2 | |
| 3 | rgsaddle | 10128 | 0.0% | 10128 | |
| 4 | eOn | 2e+08 | 0.0% | 2e+08 |
The tables below list every ranked row, by method family and overall.
Eon rows are not yet on the harness counter.
A run short of the full set, or a run that is not the stock method, stays off the ranked table.
These archived rows rank on the value each one published, which leaves out any failure. The failure rule has no score for them, for the reason given with each.
- SoftSaddle · adaptive_HSphere-lbfgs-davidson-sm50 (the entry records no failure count)
- SoftSaddle · adaptive_HSphere-lbfgs-lanczos-sm50 (the entry records no failure count)
- SoftSaddle · adaptive_HSphere-lbfgs-lanczos-sm0 (the entry records no failure count)
- eOn (r2213) · eon-dimer-lbfgs-5-rotations-20-bowl_breakout (the entry records no failure count)
- eOn (r2205) · eon-md (the entry records no failure count)
- eOn (r2213) · eon-dimer-lbfgs-5-rotations (the entry records no failure count)
- eOn (r2213) · eon-dimer-lbfgs-20-rotations-20-bowl_breakout (the entry records no failure count)
- eOn (r2213) · eon-dimer-lbfgs-20-rotations (the entry records no failure count)
- eOn (r2213) · eon-dimer-cg-5-rotations-20-bowl_breakout (the entry records no failure count)
- eOn (r2205) · eon-dimer (the entry records no failure count)
- eOn (r2213) · eon-dimer-cg-20-rotations-20-bowl_breakout (the entry records no failure count)
- eOn (r2213) · eon-dimer-cg-20-rotations (the entry records no failure count)
Minimum mode
| Rank | Row | Cost | Unit | Hessians | FD calls | Runs |
|---|---|---|---|---|---|---|
| 1 | SoftSaddle (2019.04) · adaptive hypersphere LBFGS Lanczos | 10124.2 | force calls per search | 0 | 0 | 5000 |
| 2 | rgsaddle (0.2.2) · Dimer FIRE | 10128 | force calls per search | 0 | 0 | 20000 |
| 3 | rgsaddle (0.2.2) · Dimer L-BFGS | 10128 | force calls per search | 0 | 0 | 20000 |
| 4 | rgsaddle (0.2.2) · Dimer rotation-skip L-BFGS | 10128 | force calls per search | 0 | 0 | 20000 |
| 5 | rgsaddle (0.2.2) · Lanczos L-BFGS | 10128 | force calls per search | 0 | 0 | 20000 |
| 6 | eOn (3.6.0) · Lanczos | 2e+08 | force calls per search | 0 | 0 | 2 |
Single-ended saddle
| Rank | Row | Cost | Unit | Hessians | FD calls | Runs |
|---|---|---|---|---|---|---|
| 1 | Sella (2.6.0) · Sella | 5201.62 | force calls per search | 0 | 0 | 16 |
| 2 | SoftSaddle (2019.04) · adaptive hypersphere LBFGS Davidson | 10128 | force calls per search | 0 | 0 | 5000 |
Overall
| Row | Family | Family rank | Unit | PAR-2 | Published | Median calls | Mean calls | Hessians | FD calls | Failures | Runs |
|---|---|---|---|---|---|---|---|---|---|---|---|
| Sella (2.6.0) · Sella | Single-ended saddle | 1 | force calls per search | 5201.62 | 225 | 247.812 | 0 | 0 | crash 0, divergence 0, cap 0, wrong_stationary 4 | 16 | |
| SoftSaddle (2019.04) · adaptive hypersphere LBFGS Lanczos | Minimum mode | 1 | force calls per search | 10124.2 | 389 | 431.839 | 0 | 0 | crash 0, divergence 4884, cap 108, wrong_stationary 6 | 5000 | |
| SoftSaddle (2019.04) · adaptive hypersphere LBFGS Davidson | Single-ended saddle | 2 | force calls per search | 10128 | 1060 | 1059.76 | 0 | 0 | crash 0, divergence 0, cap 5000, wrong_stationary 0 | 5000 | |
| rgsaddle (0.2.2) · Dimer FIRE | Minimum mode | 2 | force calls per search | 10128 | 1013 | 1011.03 | 0 | 0 | crash 0, divergence 1, cap 19999, wrong_stationary 0 | 20000 | |
| rgsaddle (0.2.2) · Dimer L-BFGS | Minimum mode | 3 | force calls per search | 10128 | 1013 | 1012.16 | 0 | 0 | crash 0, divergence 0, cap 20000, wrong_stationary 0 | 20000 | |
| rgsaddle (0.2.2) · Dimer rotation-skip L-BFGS | Minimum mode | 4 | force calls per search | 10128 | 441 | 479.98 | 0 | 0 | crash 0, divergence 19718, cap 262, wrong_stationary 20 | 20000 | |
| rgsaddle (0.2.2) · Lanczos L-BFGS | Minimum mode | 5 | force calls per search | 10128 | 1002 | 998.34 | 0 | 0 | crash 0, divergence 4068, cap 15932, wrong_stationary 0 | 20000 | |
| eOn (3.6.0) · Lanczos | Minimum mode | 6 | force calls per search | 2e+08 | 3.98507e+06 | 3.98507e+06 | 0 | 0 | crash 0, divergence 0, cap 2, wrong_stationary 0 | 2 |
A row that counts another unit is ranked in its own table after the overall table.
Ranked in force calls per campaign
These rows count force calls per campaign. The tables above count force calls per search, so these rows are ranked only among themselves.
The cost in the v2 scoring table is one displacement search. The archived force_calls is the mean over campaigns of each campaign's total: done.py and get_data_for_web_benchmark.m add every search until the campaign ends, and the benchmark website's Nf is the total number of force calls. force_calls / total_searches is the mean cost of one search, but the archive states no per-search cap. The PAR-2 that ranks the harness rows needs one, so the archived rows keep their own unit.
| Row | Family | Family rank | Unit | PAR-2 | Published | Median calls | Mean calls | Hessians | FD calls | Failures | Runs |
|---|---|---|---|---|---|---|---|---|---|---|---|
| SoftSaddle · adaptive_HSphere-lbfgs-davidson-sm50 | Single-ended saddle | 1 | force calls per campaign | 423491 | 423491 | 0 | 0 | not recorded | 10 | ||
| SoftSaddle · adaptive_HSphere-lbfgs-lanczos-sm50 | Minimum mode | 1 | force calls per campaign | 814519 | 814519 | 0 | 0 | not recorded | 10 | ||
| SoftSaddle · adaptive_HSphere-lbfgs-lanczos-sm0 | Minimum mode | 2 | force calls per campaign | 1.00343e+06 | 1.00343e+06 | 0 | 0 | not recorded | 10 | ||
| eOn (r2213) · eon-dimer-lbfgs-5-rotations-20-bowl_breakout | Minimum mode | 3 | force calls per campaign | 1.34547e+06 | 1.34547e+06 | 0 | 0 | not recorded | 9 | ||
| eOn (r2205) · eon-md | Single-ended saddle | 2 | force calls per campaign | 1.47817e+06 | 1.47817e+06 | 0 | 0 | not recorded | 9 | ||
| eOn (r2213) · eon-dimer-lbfgs-5-rotations | Minimum mode | 4 | force calls per campaign | 1.68444e+06 | 1.68444e+06 | 0 | 0 | not recorded | 9 | ||
| eOn (r2213) · eon-dimer-lbfgs-20-rotations-20-bowl_breakout | Minimum mode | 5 | force calls per campaign | 2.73231e+06 | 2.73231e+06 | 0 | 0 | not recorded | 9 | ||
| eOn (r2213) · eon-dimer-lbfgs-20-rotations | Minimum mode | 6 | force calls per campaign | 3.34149e+06 | 3.34149e+06 | 0 | 0 | not recorded | 9 | ||
| eOn (r2213) · eon-dimer-cg-5-rotations-20-bowl_breakout | Minimum mode | 7 | force calls per campaign | 3.4637e+06 | 3.4637e+06 | 0 | 0 | not recorded | 9 | ||
| eOn (r2205) · eon-dimer | Minimum mode | 8 | force calls per campaign | 3.77888e+06 | 3.77888e+06 | 0 | 0 | not recorded | 9 | ||
| eOn (r2213) · eon-dimer-cg-20-rotations-20-bowl_breakout | Minimum mode | 9 | force calls per campaign | 7.17421e+06 | 7.17421e+06 | 0 | 0 | not recorded | 9 | ||
| eOn (r2213) · eon-dimer-cg-20-rotations | Minimum mode | 10 | force calls per campaign | 7.94707e+06 | 7.94707e+06 | 0 | 0 | not recorded | 9 |
Off the ranked table
- eOn (3.5.0) n=10, not yet on the harness counter.
- eOn (3.5.0) n=10, not yet on the harness counter.
Success on this problem: index 1 at eigenvalue tolerance 1e-6, force norm at the stop, barrier below 1.5 eV, and exactly one minimized endpoint the same structure as the minimized minimum.
Two structures are the same when every atom is closer than distance_difference to its own position in the other (minimum image, atoms by index), as eOn Matter::compare.
A connected saddle within energy_difference of the barrier of a connected saddle already found, and the same structure as it, is a repeat (eOn AKMCState.find_repeat).
Only connected saddles enter that table.